ラベル 4 legged robot の投稿を表示しています。 すべての投稿を表示

2013年1月6日日曜日

What's RDCS?

We're going to release RDCS on April in 2014.

Goal
My goal is an automation of farming. 

Cooperative work with workers and robots
In order to automate many tasks of farming, I need some dozen robots.
But my budget is small. 
I decided to develop low cost robots by myself.  So I use  Raspberry Pis  and cheap outlet devices.
And I thought it was necessary the management system to operate some dozen robots. In addition, it must be a system that can assist in coordinating the work of workers and robots in my farm. I decided to develop the system that support a cooperative work with workers and robots.

 "RDCS" is an abbreviation of ”Robot Distributed cooperative System".
RDCS offers  the cooperative work space which share to work with workers and robots  in their  work-place. Therefore, RDCS manages the  some dozen low cost robots for a farming based on RDCS Work Definition Control.

My most priority of developing RDSC is the Safety of worker.
In the cooperative environment of worker and robots, the Safety of worker is the most important  matter. RDCS realize the Safety environment for worker and robots.
RDCSは、人とロボットが”安全に”協調して働く空間を提供します。その為に、RDCSは、WDCに基づいて多くの低コストロボットを制御します。RDCSにおいては、安全を全てにおいて最優先しています。

RDCS realizes the environment that low cost  robots can use high performance resource on network such as image processing service, space recognizing service and more.
Because of this, low cost robots can have high level functions.
And RDCS offers the integrated control to manage some dozen autonomous robots. 
Also, RDCS provides functions to support a cooperative work between workers and robots.

I understand that  to develop RDCS is very difficult to me.
But I love to create a new technology, because I am an engineer.
Challenge!
I believe that  the creation is the nature of humanity.     v(^o^)v


RDCSは、一連の作業を人と自律型ロボットが協調して行う事をサポートする統合運用管理システムです。もちろん、ロボット開発プラットフォームにもなりますが、元々の発想は運用重視からです。
単体のロボットだけでは、なにもできません。人と多くのロボットが協調して作業できなければ、ロボット導入の意味はありません。こういう、発想の研究がないんですよね。それは、至極当然かもしれません。
私は、組織の知識創造の研究をし、分析・構築メソッドや、知識創造支援システムなどの製品を開発しました。多くの大手企業に導入されて使われています。そのベースになった「組織活動プロセスモデル」を改良した新たなモデルをベースに「作業安全を重視した人とロボットの協調作業プロセス・環境のデザインと、マネジメントシステム」の開発をしています。モデルがなければ、デザインが出来ないし、デザインが出来なければ、PDCAが回せないので、改善できません。PDCAを回して、改善すると言う考え方は、日本の研究機関にはない考え方でしょう。
この様な視点には、学際的なアプローチや、実際のマネジメントの経験が必要となります。
私は、幸いな事に社会科学、経営学、工学、そしてコンピュータの分野を理解しており、かつマネジメントもしていたので、それらの経験が役立っているのだと思います。

ところで、近年の日本のコンピュータサイエンスが、どのような成果を産み出しているのか知りません。しかし、依然、新しいコンピュータ製品、ソフトの大半が海外製である事を考えれば、、、、、、
そして、Raspberry Piの開発動機の一つが、「イギリスのコンピュータ科学の学生の質が落ちたから」と言う事だそうです。日本は、どうなんでしょうか? また、学生だけなのでしょうか?

peace!

2012年12月30日日曜日

Robot Brothers and motion teacher

My robot brothers and motion teacher(center) are here!

These robots use Raspberry PI as robot controllers.
Brothers
Older son.  4 legged robot (1/2 scale prototype)
The second son.  Wheel robot (testing machine)
Robot Distributed Cooperative System (RDCS)
&
4 Dimension Space Database (4DS)

Service Server

peace!

2012年12月16日日曜日

New Raspberry Pis and Cases

I received 2Raspberry Pis and 3 cases.
I had been waited for 20 weeks.
But....
2 Rapis I received are "Made in China".
Why?
Not UK   ?(>_<)?
I think Rs is not very precise.

peace!

2012年11月15日木曜日

Moving Control Flowchart and Moving Mode of 4 legged robot

The below figure is a flowchart of moving control.
Moving control is able to call as a 'Moving Control Service'.
This flowchart is a part of RDCS.


My 4 legged robot has 5 moving modes.

(1) On board mode
    This mode is to move mounting a harvesting machine and other working machines.
    An importance function of this mode is to move with keeping machines in a horizontal position.
(2) Walking mode
    This mode is to walk  with  loading a  package(20Kg).
(3) Traction mode
    This mode is to tractor other robot and carts.
        sample --> http://robot009.blogspot.jp/2012/10/prototype-robot-movie.html
(4) Climb and down stairs mode
    This mode is to climb up stairs and to down stairs with a light load package
(5) ike-ike mode
    This mode is to accomplish on the irregular ground.

My 4 legged robot automatically adjust its moving  mode to the situation.

I have built up a prototype robot to validate the above functions.
At the result, I've found many issues, improvements and bugs, so I'm improving away off.
On the other hand, I feel increasingly confident that RDCS is  beneficial.
(RDCS is a robot development platform.)


"Requester"  is " upper level programs or services of RDCS.
"RDCS Servicer"  is common functions of RDCS such as "4D Space Database",  Space recognition", "Obstruction Detection" and other functions.

RDCS: Robot Distributed Cooperative System
             --> http://robot009.blogspot.jp/2012/09/update-rdcs.html

私が開発している4脚 歩行 ロボットは5つの移動モードを持っています。
農作業の様々場面で、活動する為にはこれらの複数のモードが必要です。
私のロボットは、分散コンピューティングの考え方を基本にしています。
つまり、計算リソースは、必要に応じて組合わせる事ができます。
下の図は、RDSCのMoving Controlのフローです。
詳しい説明はしませんが、こんな感じです。
開発しながら、Documentを、残さないと大変なことになるので、、、
学者風に説明すれば、かなりの量の論文が書けます。
特に、自己再帰的に、4脚を制御して、路面に合わせて最適な接地位置を選択する
機能なんか、とっても面白い、論文になります。
4脚ロボットは、かなり面白いです。また、応用の範囲が大変広いです。

そのひとつが、Actuatorです。逆に開発しなくてよかったなぁと思います。
しかし、最近は、昼間は本職(農業)で、夕方からロボット開発で、毎晩遅くまでやっています。
でも、すげー楽しいです。
特に、4脚歩行のmotion データの自動作成プログラムや、空間認識プログラムは、錆付いた脳みその、お掃除に最適です。

英語の内容と違った内容になってしまった。まぁ、いいかぁ


By the way, I am a farmer. (*^^)v
This morning, I sprinkled the lactobacillus on the ground of my farm.
I use the lactobacillus to improve the microbial environment of the soil in my farm.
This picture is the shot of  pouring the home fermentation lactobacillus out of the bottle to the water pot. To sprinkle the lactobacillus on the farm, I usually dilute by 1%.


この写真は、自家製の乳酸菌を作物や土に散布する為に、じょうろに移している場面です。
今朝の乳酸菌を、畑に撒く準備をしている時に、写しました。
乳酸菌を定期的に土に散布すると、土壌中の微生物環境を良い状態に保てます。
農業を始めてから乳酸菌を使い、いろいろ効能を検証してきましたが、3年間の経験から言うと、


・乳酸菌を薄めるときには、直接水道水を使わない。
 塩素が、影響して菌が死にます。
 私は、ビタミンCを使って還元した水道水を使います。


・土中の環境改善に効果がある。
  土中の環境改善により、病原菌が減り、かつ虫も減ります。
  また、土中の菌が増えるので、根の周りの環境がよくなり、
  結果的には、美味しい野菜になります。
  特に、タマネギには効果絶大です。

・防虫/殺虫効果は、単体利用では期待しないほうが良い。
 確かに、乳酸菌は酸なので、PH4程度に薄めた液は、強酸ですから
 アブラムシなどに若干の効果がありました。しかし、同時に葉面の菌を殺すことにもなります。
 私が、効果のあると認識しているのは、弱酸性にして、アルカリ性のものと、
 交互に散布する方法です。水ナスなどでは、虫がつかなくなります。
 2年続けて、露地栽培で、化学農薬を使わない水ナスを作ることができました。

 最近は、水ナスにつく虫や病原菌に化学農薬が効かないという話を聞きます。農薬で洗い流すように、農薬を丁寧に散布しているそうです。であれば、農薬の本来の意味がありません。
 数十年以上化学農薬を使い続けているので、基本的に農薬を使った営農方法に、害虫のライフ
 サイクルが、お温暖化の環境と相まって、適応しているのかもしれません。
 私も、乳酸菌を薄めた液で、ナスについたアブラムシを洗い流す時もありますが、翌日は、
 ほのかにヨーグルトのにおいがします。(営農1年目です。今は、アブラムシがつかないので
 そのような使い方はしません)

以下は、私の主観的な考えですが、、、、、
 私の方法は、葉面菌と共存できる状態で弱アルカリ性と弱酸性の両方の環境を、
 交互に人工的に発生させて
 「ここはなんか、おかしい卵をうみたくない」と”遺伝子の深いところにある部分に、生理的に感じさせている”のかもしれません。 基本的に、病原菌や虫は、中性の状態を好みます。
化学農薬に対する記憶は、遺伝子の中にはないですから虫は避けないのではないでしょうか?避けなければ、生き残った虫は、耐性を持ってしまうのは、考えられることです。
また、化学農薬の多くは、中性ではないでしょうか?

農薬で洗い流すような撒布方法をするのであれば、ロボットでは無理だと思います。この方法は、葉を一枚一枚洗う為に、高圧で散布する農薬を被ることになります。
しかし、葉面に霧状の散布をするのであれば、ロボット的な作業工程を組み立てることができます。

アブラ虫を寄り付かせない為には、防虫テープが、大変効果を発揮します。
確か、農業試験場の実験報告もあります。
私は、ナスやトマトハウスの周りにも、張っています。
テープで囲まれた内側に虫を捕捉するテープを張り、1週間程度様子を見ると、
テープで囲んだ箇所と、囲んでないところでは、見た目で効果が比較できます。
地上から0.5m、1m、1.5mの間隔で張れば十分です。
風に吹かれて、ユラユラすると、光が乱反射されて、虫が方向感覚を失うそうです。

化学農薬利用のドグマにはまり込んでいる、農業現場です。
ここには、TPPは関係ありません。

ロボットの話から、、、脱線しました。

Peace!

2012年11月9日金曜日

I'm a farmer. v(^o^)/ young daikon & digging taros from Sulawesi

Young Daikon (Japanese radish)


Kurin could smell taros in the ground.
Kurin struggled frantically to dig taros.
Robots can't do same things, because I can't code program of the taro's smell in the ground.

   His face oh........怖い


Peace!

2012年11月1日木曜日

Now status of developing a 4 legged prototype robot

front or back

side

back or front


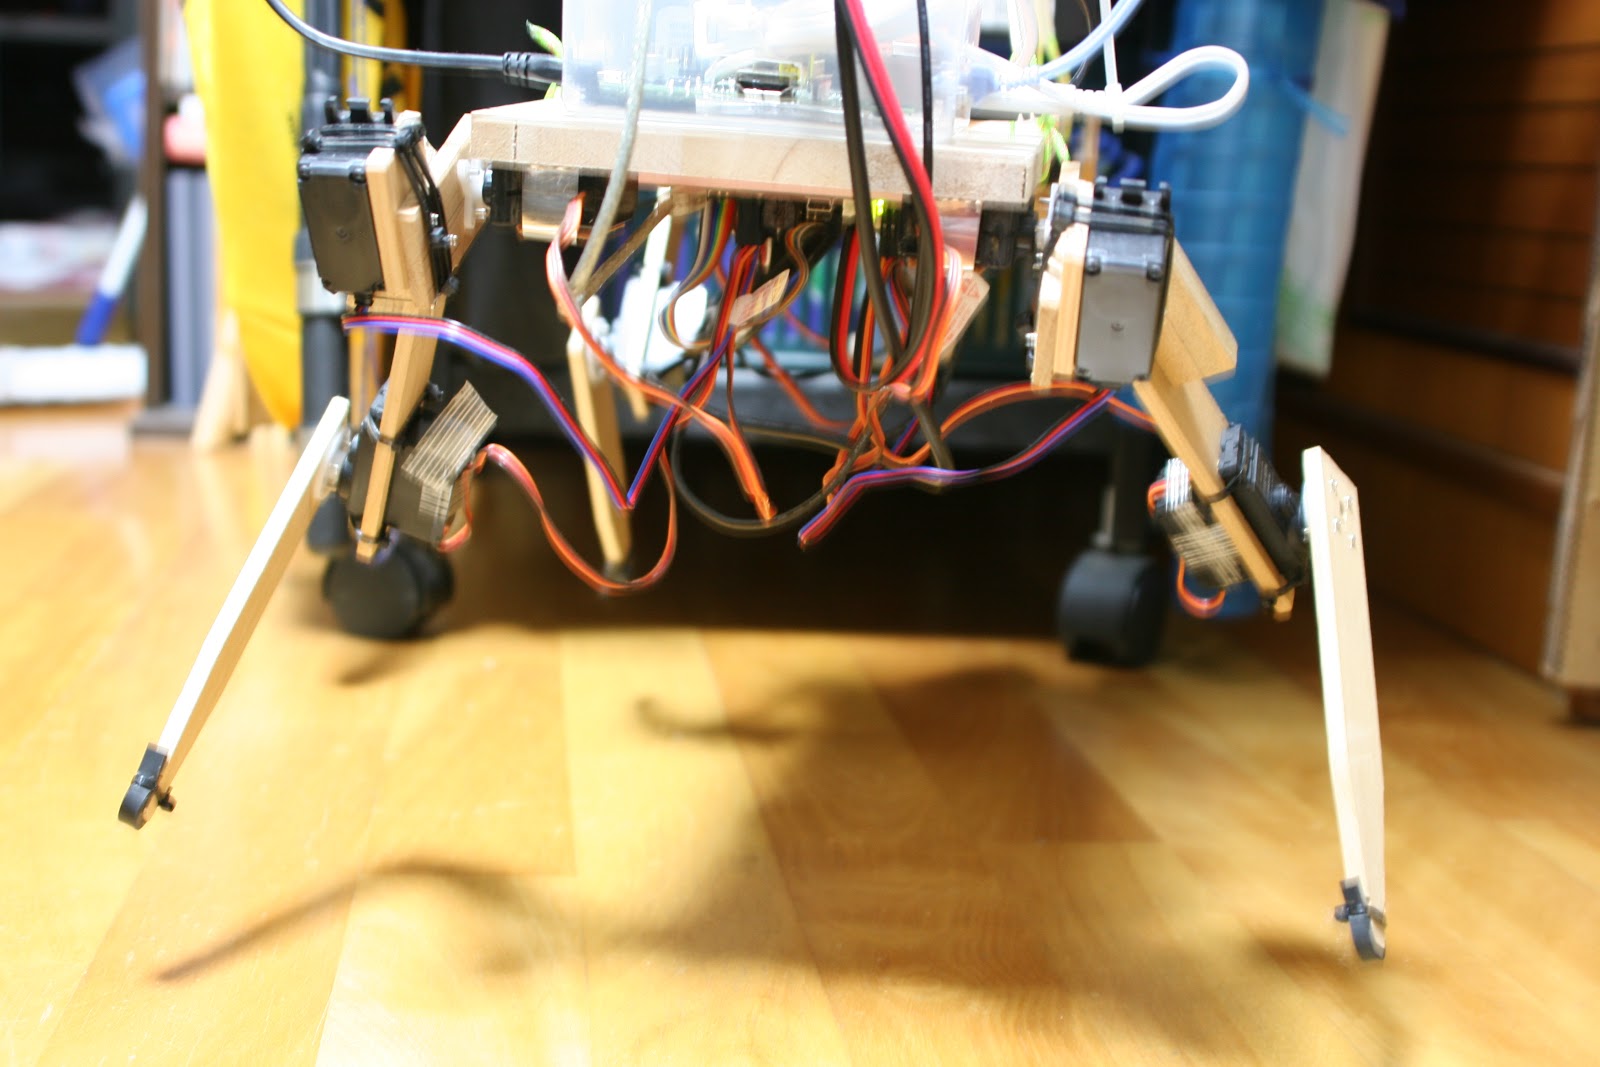
There are 3 joints in back leg joints and 2 joints in front leg.
The reason is to improve turning capability, climbing stairs and moving on rough terrain.

The structural material is wood.
Because wood is easily-worked.
But production model  will be built up using aluminum(A5052).


     Now considering,,, I think it might be woody robot is good.
     If the junctions of structure are reinforced by  aluminum parts,
     woody material has enough strong material stress, easily-worked,
     eco, low cost, easy purchase and warmth to people.
     (Nov. 3, 2012)


This prototype uses 10 servos.
But production model will use motors to reduce the robot cost.

Xtion is an important part of my space recognizing system.
I realize a space recognizing system using Xtion, lots of visual processing program and space DB.
And I use an IR Distance Measuring Sensor Unit to detect an obstacle  in short range.

As a result,  I've developed  a technology to make a 4 legged robot  that can transport a package ( 20kg). And then the robot production cost is less than $1,000.

Next, I have to develop an actuator for tomato harvesting.
It will ride on the 4 legged robot.


Challenge !!

2012年10月31日水曜日

Hello! Robot motion teacher and student.


Peace!

I'm a farmer. v(^o^)/ cultivate plants using cell tray

Plants are growing.
(Seeded on  Oct. 20, 2012)

   \(^0^)/    Refreshed morning.
tomato
daikon (大根) Japanese radish
spinach (法蓮草) and others
onion
cabbage
broccoli
They look at the Sun.
broccoli
......    ......    ......    ....   ...   ..   .

Happy!

2012年10月30日火曜日

Design a motion of 4 legged robot


I have designed a motion of 4 legged robot using following document.
This document describes a motion pattern and how to move each legs, heels and body.
I have been testing effective walking of 4 legged robot for a half month.
I have gathered data and wrote the document. And I have  coded the walking program of 4 legged robot.


Peace!

New house & new machine

Kurin is happy.
Because he has a new house.
Now Japan is autumn, It will be winter soon.
I wonder if his house will warm KURIN in winter.

A new cutting machine!
I use this machine to make a robot part.
It can cut materiales at a right angle.
To cut materiales at a right angle is very important to build up robots.
Hitachi  Koki      FC7FSB


Peace!

2012年10月29日月曜日

The Video !! Walking a 4 legged robot. v(^.^)v

Please see a  prototype robot video.
It's a powerful  4 legged robot.


This prototype robot is used for functional verification.
It seem a simple robot, but it have many function.
Space recognition, obstacle detection,  autonomous locomotion,,,,

These function is  on my original robot platform called 'RDCS'.
I will improve these robot function  using  results of prototype robot testing.

By the way, he recognizes  his environment through his eye (xtion).

Peace!

2012年10月19日金曜日

Useful robot work bench.


I made a robot work bench yesterday. I could understand it is very useful.
The photo is a scene of test recognizing target.
I can move a Xbox on bench smoothly and easily.


  Peace!

Now status:4 legged robot. New robot bench.


I'm developing a motion realtime generation program for my 4 legged robot.
It's very difficult program for me.  I'd like to develop the program in this week.
I made a robot bench.  When I debug a motion realtime  generation program, i use this bench. It took 4 hours to make this bench.
Now I develop a prototype 4 legged robot. This bench is able to use too, when  i will develop a next robot which work in my farm and greenhouse.


 prototype 4 legged robot 
prototype 4 legged robot (front)

robot bench

robot bench

peace!